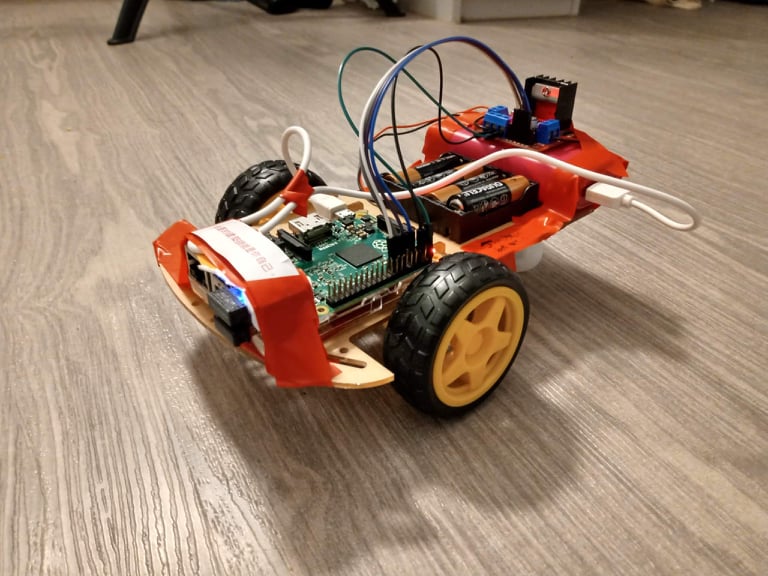
JimJamBot - Raspberry Pi Based Rover
This month after completing my computer systems module, I became more and more interested in controlling hardware with computers. I had an old Raspberry Pi 2 that I haven’t done anything with in ages, so I decided to order some parts and make a little rover. I have a basic working prototype and big dreams for what he could become :D
Right now, I can control the rover remotely using SSH, and it can move forwards, backwards and turn. This is done through a simple python program that will send a signal to the GPIO pins, which then in turn go to the wheels.
I had to do quite a bit of adjusting due to the fact it only has two wheels, and because the parts are cheap the amount of power going to the wheels isn’t always even (meaning it can tilt more to one side than the other when moving sometimes). I plan to buy another set of wheels soon so there are 2 on each side, and I think this should balance out these issues a bit.
There is also a camera attached to the front of the rover, so you can see where you are going when controlling it remotely. I can livestream this camera to the host PC using RPi cam interface on the pi.
Your browser does not support the video tag. Ignore my coughing I was quite ill when filming this lol
Future Plans
As I said, I’d love to upgrade the hardware first so that the rover is a bit more stable. I have also bought some ultrasonic sensors, so I would like to set those up and maybe eventually get the rover to be autonomous.